Product
Product
News
Featured


Contact Us
Contact: POWER DUKE
Phone: +86 18059884790
E-mail: plc66@qq.com
Add: fujian xiamen
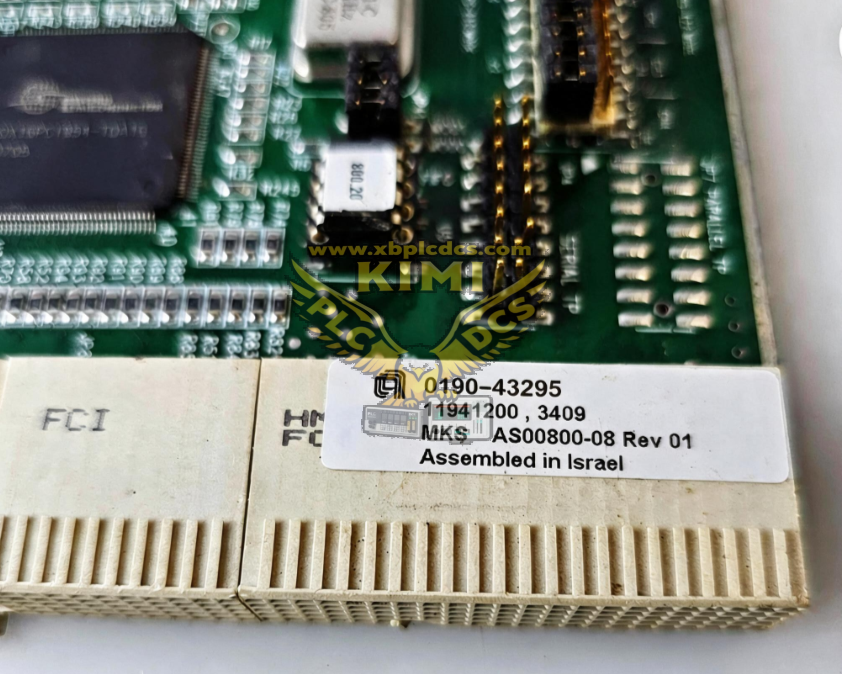
Applied Materials 0190‑43397 Wafer Robot Controller PCB Assembly
- Warehouse: Spot
- Warranty: 365 days
- Quality: Original module
- Condition: New
- Shipping method: Courier delivery
- Contact person: LI MING
- Contact number: +86 18059884790
- WeChat:18059884790
- E-mail: plc66@qq.com
Product Description
Applied Materials 0190‑43397 Wafer Robot Controller PCB Assembly
Product Description
0190‑43397 is a dedicated multi‑axis motion control PCB assembly for AMAT wafer handling robot, deployed on Centura / Endura cluster tools. The board integrates servo drive circuits, encoder signal acquisition, position‑loop computation, safety interlock logic and tool host communication interface. It executes precise trajectory planning for wafer transfer arm, handling wafer pick‑and‑place, alignment and transfer between load‑lock, cassette and process chambers in 200 mm / 300 mm semiconductor fabrication environment.
Key Functions
- Multi‑axis closed‑loop servo control for robot rotation, extend, Z‑lift axes; high‑resolution encoder position feedback
- Trajectory profile generation: velocity, acceleration and jerk limiting for smooth wafer transfer, minimizing particle generation
- Wafer presence sensor signal processing, edge detection and offset alignment calculation
- Hardware safety interlock: over‑torque, soft‑stop, collision detection, emergency stop chain monitoring
- Host communication over industrial bus: upload axis position, velocity, fault codes and robot status; download motion recipes from tool main controller
- Built‑in diagnostic counters for move cycles, fault events for predictive maintenance analysis
Application Scenarios
- Applied Materials Centura, Endura cluster semiconductor platforms
- PVD, CVD, Etch process chamber wafer handling subsystem
- Load‑lock and cassette wafer transfer robot control
- 200 mm & 300 mm wafer fab clean‑room high volume manufacturing
Common Issues & FAQ
- Robot position offset / wafer mis‑pick: Inspect encoder wiring and connector integrity; perform home‑position calibration; check for mechanical backlash on robot arm joints; verify sensor signal levels.
- Collision detect fault triggered: Review motion recipe speed‑acceleration parameters; check for mechanical obstruction; inspect torque threshold setting; check board servo output channel health.
- Axis motion timeout / no movement: Verify 24 V / 48 V power input and fuses; check servo motor harness; inspect board drive components; confirm host command reception.
- Interlock alarm cannot be cleared: Trace E‑stop chain, door interlock and wafer sensor inputs on board terminal status via service menu.
- Refurbished unit note: After replacement, complete axis homing, position accuracy validation, full cycle wafer transfer test and interlock safety test before production release.
Related recommendations